Kodiak 3D Lidar
Optics
Kodiak 3D Lidar (GSC-TOPS-212)
Provides low cost and highly reliable 3D lidar images in nearly any lighting condition.
Overview
High orbit satellite servicing and planetary science missions are presented with unique challenges, including a harsh environment and long mission life, coupled with the need for long range and high speed and accurate measurements. Conventional systems suffer from high costs of bringing other solutions to market and questionable reliability.
The Technology
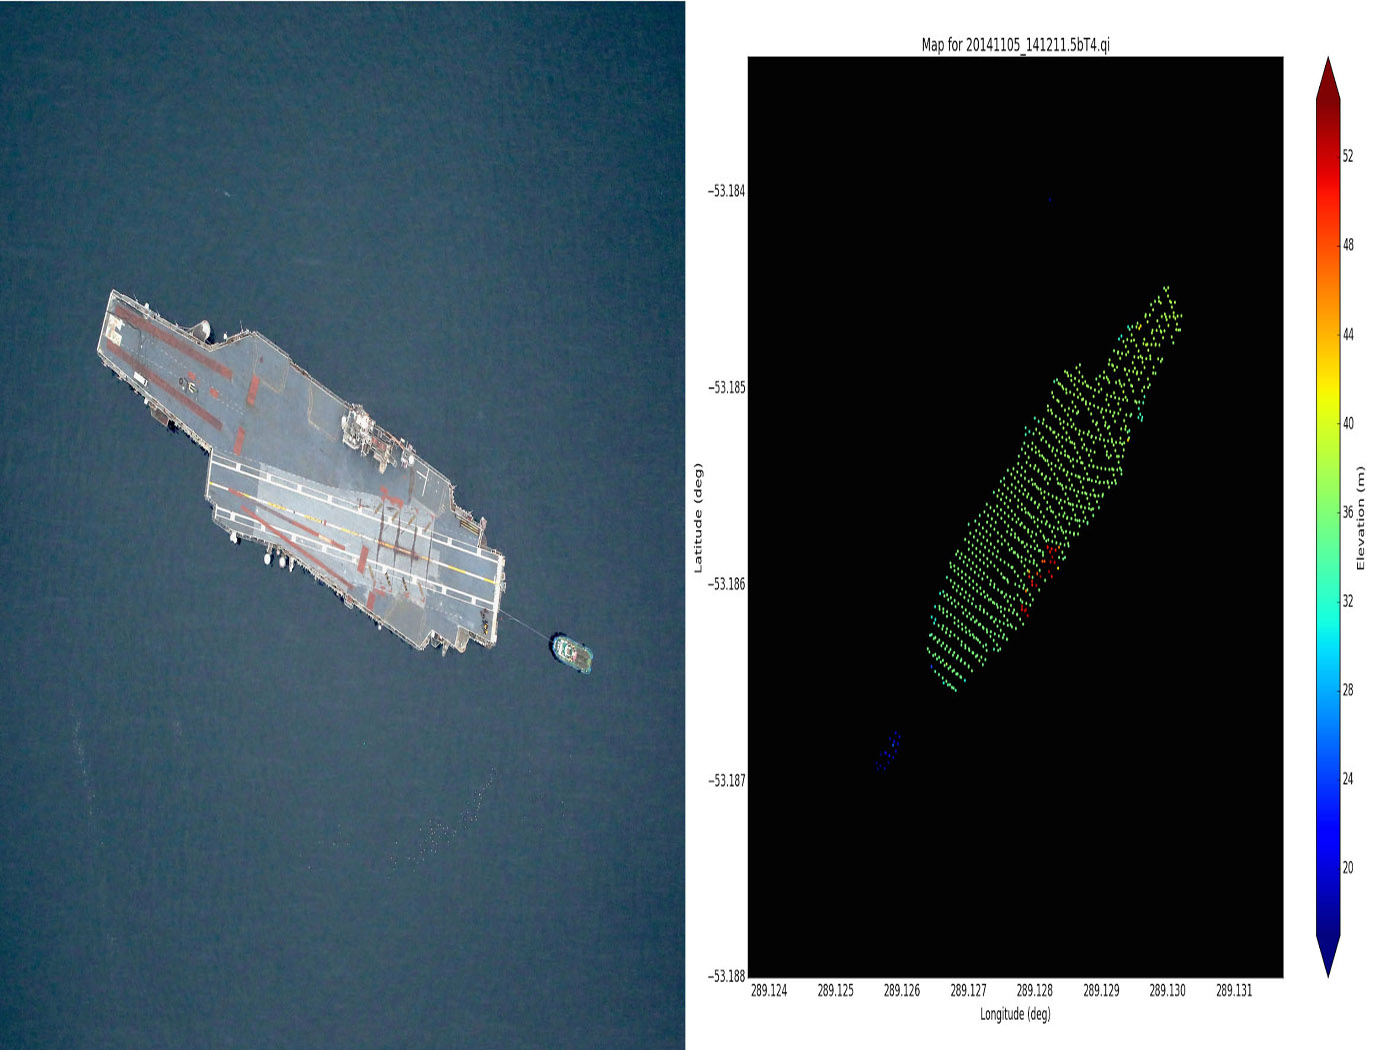
NASA Goddard Space Flight Center has developed a 3D lidar system that consists of microelectromechanical systems (MEMS) beam steering, high performance reconfigurable computing, and an in-depth understanding of systems level integration. Kodiak combines a 3D MEMS scanning lidar with a long range narrow FOV telescope to produce a flexible and capable space flight ranging system. Also included is SpaceCube-level processing power to host a variety of algorithms enabling sensing and 6 degrees of freedom.
Benefits
- Lower cost
- Higher performance and reliability
- Reconfigurable
- Low SWaP
- Capable of generating 3D imaging in nearly any lighting condition from long ranges
Applications
- Space detection and ranging
- Proximity laser ranging
- Autonomous vehicles
Technology Details
Optics
GSC-TOPS-212
GSC-18054-1
Patent Pending
Similar Results

Client Berthing System (CBS)
The Client Berthing System (CBS) was originally designed for NASA’s On-orbit Servicing, Assembly, and Manufacturing 1 (OSAM-1) spacecraft, which will grapple and refuel the LandSat 7 satellite. After the OSAM-1 spacecraft has rendezvoused with LandSat 7, a robotic arm equipped with a gripper tool will autonomously grapple the satellite’s Marman ring (launch separation ring) and affix it to the CBS in the appropriate refueling position. The CBS is comprised of three posts protruding from the servicing satellite, each with integrated berthing mechanisms, distributed in a radial pattern of 120° along the client’s Marman ring diameter. Each berthing mechanism includes a rotary clamping jaw with a drawdown and radial contact portion. The clamping jaws are actuated by a motor-driven leadscrew and guided by recirculating linear ball bearings.
After the servicing spacecraft’s robotic arm has placed the client satellite Marman ring into the CBS berthing box, the clamping jaws simultaneously move radially inward towards the center of the ring. The lead-in features of the jaws exert downward pressure on the ring, driving it towards the jaw palms as the lead-in portion rises over the surface of the ring flange. Once the flange is drawn down such that it contacts the radial clamp surface of the jaws, force is exerted causing the jaws to pivot, driving the underside of the lead-in surfaces into contact with the upper flange surface. As the jaw mechanisms continue to drive, increased axial load squeezes the ring flange between the lead-in-feature and palm of the jaws, stabilizing the connection. At a predetermined load, brakes are engaged, and system motors shut off. A NASA-developed Marman ring location detection system is employed to guide the berthing process.
NASA has developed a suite of cutting-edge technologies that can help your business develop robust satellite servicing offerings. For additional information, please see the NASA Satellite Servicing Technologies Available for Licensing link provided.

Miniaturized Astrometric Alignment Sensor
The Miniaturized Astrometric Alignment Sensor advances satellite capabilities for astrophysical measurements, necessary for formation flying, relative navigation, and virtual telescope capabilities. The sensor is a single assembly consisting of a small, low powered camera assembly. The sensor detects stellar objects from which both stellar and object tracking are performed. The sensor’s components consist of a low power camera assembly, interchangeable lenses, camera power supply, and image processing software and algorithms. The system functions by searching and identifying objects in the camera's field of view and tracking the objects against a selected star pattern with a central body of interest in the sensor's field of view.
The Miniaturized Astrometric Alignment Sensor makes it possible to measure a spacecraft’s altitude and orientation with respect to known stellar objects. The instrument takes an image of a patch of sky, identifies the stars in that field of view, and compares the field view with a stored star map. The data is processed with a dedicated processor attached to the instrument to spell out the attitude and orientation of a spacecraft.

GPS-Enhanced Onboard Navigation System (GEONS)
While real-time positioning computed by standard GPS service is adequate for some onboard applications, inherent position discontinuities are not acceptable for high-precision instrument applications, such as view-period prediction and maneuver planning, both of which are computations that require a continuous prediction of the spacecraft state. Real-time positioning also requires simultaneous measurements from four GPS satellites, a mission-limiting factor that must be considered.
GEONS processes data from standard GPS receivers, onboard communication equipment, and/or attitude sensors, producing accurate absolute and relative navigation solutions in real time. Other functions, including onboard maneuver control and relative navigation for keeping formations are also supported by GEONS. All information is quickly available to scientists when it is included in the down-linked telemetry stream.
GEONS provides high-quality solutions with fewer than four visible GPS space vehicles by employing an extended Kalman filter (EKF) augmented with physically representative models for gravity, atmospheric drag, solar radiation pressure, clock bias, and drift to provide accurate state estimation and a realistic state error covariance. GEONS incorporates the information from all past measurements—carefully balanced with GEONS’ data of the physical models governing these measurements—to produce an optimal estimate of the user spacecraft’s orbit. GEONS’ high-fidelity state dynamics model reduces sensitivity to measurement errors and provides high-accuracy velocity estimates, permitting accurate state prediction during signal outages or degraded coverage.
Autonomous navigation reduces total mission cost by eliminating the need for routine, ground-based orbit determination and special tracking services, and it is required for advanced mission concepts, such as satellite formation flying. GEONS was designed for autonomous operation within the very limited resources of an onboard computer. Autonomous initialization and enhanced fault detection capabilities are implemented using instantaneous geometric GPS solutions.
By incorporating information from past measurements, GEONS provides highly accurate orbit estimates even with one visible GPS space vehicle—and even during signal outages or degraded coverage. This unprecedented accuracy and reliability reduces navigation errors and does it autonomously with minimal onboard computer resources.
Additionally, GEONS processes Doppler measurement data from onboard attitude sensors. These different types of measurements are all incorporated into the GEONS software, producing a navigation system capable of handling multiple orbit regimes and navigation subsystems, while requiring no additional hardware. Fusion of these data types increases system stability and reliability and enables graceful degradation in the event that a component fails during orbit.

DellingrX Small Satellite Spacecraft Bus Architecture
DellingrX Small Satellite Spacecraft Bus Architecture tailors balancing and scaling of programmatic and technical risks for Class-D missions. The architecture is inherently single-string but pushes probability of mission successful by implementing features to increase robustness and graceful degradation of core functionality. Additional autonomy is included in the architecture, its fault protection, and modes of operation to reduce operations costs and to fly through and recover from benign faults. The architecture reduces size, weight, and power while increasing flexibility and robustness by tightly integrating electronics and software for core subsystems and standardizing interfaces for more mission unique components.
The DellingrX architecture is highly integrated and leverages flexibility inherent in FPGAs and software. The onboard reconfigurability allows each mission to tailor the performance versus reliability and component configuration to meet specific needs. The architecture also tiers the functional reliability and hardware that performs those functions.

On-demand, Dynamic Reconfigurable Broadcast Technology for Space Laser Communication
NASA Goddard Space Flight Center has developed a configurable phase mirror system that can address likely obstacles in space optical communications. Through using miniature adjustable mirrors and programmed phase delays to diffract a single communication beam, numerous diffracted beams can be sent to other satellites in various directions for communication and tracking. The initial laser beams wave profile can be dynamically regulated through a fast Fourier transform (FFT) so that when it reaches its desired destination, it forms an intended illuminated spot at the target satellite. Since all the diffracted beams share the same phase mirror, the antenna gain needed to broadcast these beams does not require a multiplied aperture.