Search
PATENT PORTFOLIO
On-demand, Dynamic Reconfigurable Broadcast Technology for Space Laser Communication
NASA Goddard Space Flight Center has developed a configurable phase mirror system that can address likely obstacles in space optical communications. Through using miniature adjustable mirrors and programmed phase delays to diffract a single communication beam, numerous diffracted beams can be sent to other satellites in various directions for communication and tracking. The initial laser beams wave profile can be dynamically regulated through a fast Fourier transform (FFT) so that when it reaches its desired destination, it forms an intended illuminated spot at the target satellite. Since all the diffracted beams share the same phase mirror, the antenna gain needed to broadcast these beams does not require a multiplied aperture.

Visual Inspection Posable Invertebrate Robot (VIPIR)
Initially developed as a close quarters inspection tool capable of accessing hard to reach, tight, or visibly restricted, areas of satellites, the VIPIR system can be used to remotely inspect inaccessible locations such as behind a sheet of thermal blanketing material, into a satellites plumbing, or perhaps even deep inside the otherwise unreachable crevasses of a spacecraft bus. The VIPIR system incorporates a number of subassemblies for incredible operational freedom and capabilities for imaging and dissemination of componentry.
VIPIR’s Video Borescope Assembly (VBA) is a flexible snake-camera capable of multidirectional articulations, making steering and control simple and intuitive for an operator. The VBA also includes at least one imaging sensor and lighting to see in dark, confined spaces. Real-time, high-resolution visual information can be fed back to an operator for live analysis. A reel system extends and retracts the VBA with the use of a spool, and includes position indicators for deployment tracking. The Tendon Management System (TMS), not unlike human tendons, utilizes pulleys and tensioners to articulate the VBA in the confined spaces. A seal system ensures the VBA is free of contamination.
VIPIR underwent space-based testing on the ISS during the Robotic Refueling Phase 2 (RRM-2) mission designed to showcase and test several NASA advanced robotic satellite servicing technologies. During this mission, VIPIR demonstrated state-of-the-art near and midrange inspection capabilities. NASA’s VIPIR system is available for licensing to industry, and may be desirable to companies focused on satellite servicing, on-orbit assembly, and other applications requiring detailed inspection of assets in space.

Client Berthing System (CBS)
The Client Berthing System (CBS) was originally designed for NASA’s On-orbit Servicing, Assembly, and Manufacturing 1 (OSAM-1) spacecraft, which will grapple and refuel the LandSat 7 satellite. After the OSAM-1 spacecraft has rendezvoused with LandSat 7, a robotic arm equipped with a gripper tool will autonomously grapple the satellite’s Marman ring (launch separation ring) and affix it to the CBS in the appropriate refueling position. The CBS is comprised of three posts protruding from the servicing satellite, each with integrated berthing mechanisms, distributed in a radial pattern of 120° along the client’s Marman ring diameter. Each berthing mechanism includes a rotary clamping jaw with a drawdown and radial contact portion. The clamping jaws are actuated by a motor-driven leadscrew and guided by recirculating linear ball bearings.
After the servicing spacecraft’s robotic arm has placed the client satellite Marman ring into the CBS berthing box, the clamping jaws simultaneously move radially inward towards the center of the ring. The lead-in features of the jaws exert downward pressure on the ring, driving it towards the jaw palms as the lead-in portion rises over the surface of the ring flange. Once the flange is drawn down such that it contacts the radial clamp surface of the jaws, force is exerted causing the jaws to pivot, driving the underside of the lead-in surfaces into contact with the upper flange surface. As the jaw mechanisms continue to drive, increased axial load squeezes the ring flange between the lead-in-feature and palm of the jaws, stabilizing the connection. At a predetermined load, brakes are engaged, and system motors shut off. A NASA-developed Marman ring location detection system is employed to guide the berthing process.
NASA has developed a suite of cutting-edge technologies that can help your business develop robust satellite servicing offerings. For additional information, please see the NASA Satellite Servicing Technologies Available for Licensing link provided.
SpaceCube
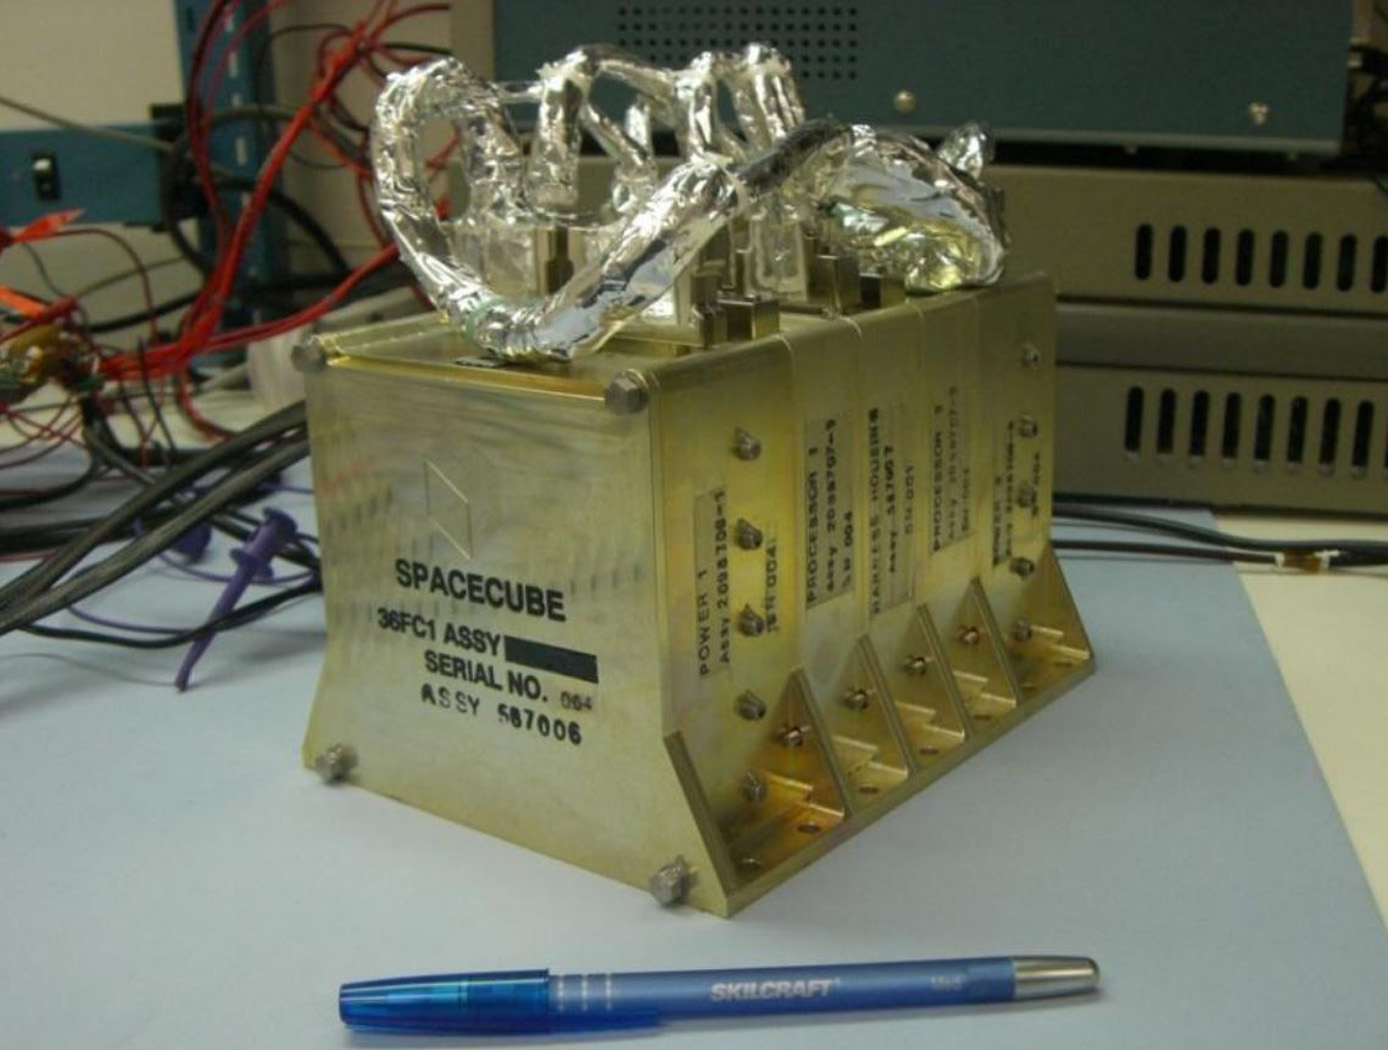
Next generation instruments are capable of producing data at rates of 108 to 1011 bits per second, and both their instrument designs and mission operations concepts are severely constrained by data rate/volume. SpaceCube is an enabling technology for these next generation missions.
SpaceCube has demonstrated enabling capabilities in Earth Science, Planetary, Satellite Servicing, Astrophysics and Heliophysics prototype applications such as on-board product generation, intelligent data volume reduction, autonomous docking/landing, direct broadcast products, and data driven processing with the ability to autonomously detect and react to events. SpaceCube systems are currently being developed and proposed for platforms from small CubeSats to larger scale experiments on the ISS and standalone free-flyer missions, and are an ideal fit for cost constrained next generation applications due to the tremendous flexibility (both functional and interface compatibility) provided by the SpaceCube system.

STELLA-1.2
The STELLA-1.2 base unit includes a microcontroller, GPS, BME280 (temperature, pressure, humidity), and rotary control with display. Sensor modules include:
• Spectrometer: 18-band VNIR from 410–940nm, UV, light, IR, lidar
• Air Quality: CO₂ (SCD-40), PM2.5/PM10 (PMSA003I), methane
• Expandability: More modules via magnetic couplers and CircuitPython menu additions

TerraROVER
The TerraROVER’s core functionality is centered around its electric propulsion system, enabling it to traverse various outdoor environments. Its drive system consists of electric motors and gearboxes that provide controlled speed and maneuverability. The remote-control interface allows users to adjust speed and direction, making it an effective platform for training and testing mobility systems. For advanced applications, the TerraROVER can be adapted for pre-programmed or autonomous navigation, expanding its use in robotics and automation research.
A key design feature of the TerraROVER is its adaptability for sensor integration. It includes mounting provisions for miniaturized sensors capable of capturing environmental data such as temperature, GPS location, and visual imagery. The platform supports both onboard data logging and real-time transmission, making it suitable for field studies, distributed sensing applications, and educational experiments. Fabrication is streamlined through the use of 3D-printed components, allowing for cost-effective production and easy assembly in classroom or research settings. Currently at Technology Readiness Level (TRL) 7, the system has been successfully demonstrated in an operational environment and is available for patent licensing.

GPS-Enhanced Onboard Navigation System (GEONS)
While real-time positioning computed by standard GPS service is adequate for some onboard applications, inherent position discontinuities are not acceptable for high-precision instrument applications, such as view-period prediction and maneuver planning, both of which are computations that require a continuous prediction of the spacecraft state. Real-time positioning also requires simultaneous measurements from four GPS satellites, a mission-limiting factor that must be considered.
GEONS processes data from standard GPS receivers, onboard communication equipment, and/or attitude sensors, producing accurate absolute and relative navigation solutions in real time. Other functions, including onboard maneuver control and relative navigation for keeping formations are also supported by GEONS. All information is quickly available to scientists when it is included in the down-linked telemetry stream.
GEONS provides high-quality solutions with fewer than four visible GPS space vehicles by employing an extended Kalman filter (EKF) augmented with physically representative models for gravity, atmospheric drag, solar radiation pressure, clock bias, and drift to provide accurate state estimation and a realistic state error covariance. GEONS incorporates the information from all past measurements—carefully balanced with GEONS’ data of the physical models governing these measurements—to produce an optimal estimate of the user spacecraft’s orbit. GEONS’ high-fidelity state dynamics model reduces sensitivity to measurement errors and provides high-accuracy velocity estimates, permitting accurate state prediction during signal outages or degraded coverage.
Autonomous navigation reduces total mission cost by eliminating the need for routine, ground-based orbit determination and special tracking services, and it is required for advanced mission concepts, such as satellite formation flying. GEONS was designed for autonomous operation within the very limited resources of an onboard computer. Autonomous initialization and enhanced fault detection capabilities are implemented using instantaneous geometric GPS solutions.
By incorporating information from past measurements, GEONS provides highly accurate orbit estimates even with one visible GPS space vehicle—and even during signal outages or degraded coverage. This unprecedented accuracy and reliability reduces navigation errors and does it autonomously with minimal onboard computer resources.
Additionally, GEONS processes Doppler measurement data from onboard attitude sensors. These different types of measurements are all incorporated into the GEONS software, producing a navigation system capable of handling multiple orbit regimes and navigation subsystems, while requiring no additional hardware. Fusion of these data types increases system stability and reliability and enables graceful degradation in the event that a component fails during orbit.
Gear Bearings
These patented gear bearings provide superior speed reduction in a small package. They form rolling friction systems that function both as gears and bearings and are compatible with most gear types, including spur, helical, elliptical, and bevel gears. These self-synchronized components can be in the form of planets, sun, rings, racks, and segments thereof. The design reduces micro chatter and eliminates rotational wobble to create smooth and precise control. It offers tighter mesh, more even gear loading, and reduced friction and wear.
Gear bearings eliminate separate bearings, inner races, and carriers, as well as intermediate members between gears and bearings. Load paths go directly from one gear bearing component to another and then to ground. By incorporating helical gear teeth forms (including herringbone), gear bearings provide outstanding thrust bearing performance. They also provide unprecedented high- and low-speed reduction through the incorporation of phase tuning. Phase tuning allows differentiation in the number of teeth that must be engaged govbetween input and output rings in a planetary gearset, enabling successful reduction ratios of 2:1 to 2,000:1. They provide smooth and accurate control with rifle-true anti-backlash. This produces a planetary transmission with zero backlash. The gear bearing technology is based on two key concepts: the roller gear bearing and the phase-shifted gear bearing. All designs are capable of efficiently carrying large thrust loads.
Existing gear systems have drawbacks including weak structures, large size, and poor reliability, as well as high cost for some types (e.g., harmon-ic drives). Gear bearings solve these problems with simpler construction, fewer parts, and superior strength.
By selecting the appropriate manufacturing method and materials, gear bearings can be tailored to benefit any application, from toys to aircraft.

Algorithms for stabilizing intelligent networks
Some of the current challenges faced by research in artificial intelligence and autonomous control systems include providing self control, resilience, adaptability, and stability for intelligent systems, especially over a long period of time, in changing environments. The Evolvable Neural Software System (ENSS), Formulation for Emotion Embedding in Logic Systems (FEELS), Stability Algorithm for Neural Entities (SANE), and the Logic Expansion for Autonomously Reconfigurable Neural Systems (LEARNS) are foundations for tackling some of these challenges, by providing the basic algorithms evolvable systems could use to manage its own behavior.
These algorithms would allow networks to self regulate, noticing unusual behavior and the circumstances that may have caused that behavior, and then correcting to behave more predictably when similar circumstances are encountered. The process is similar to how psychology in organisms evolved iteratively, eventually finding and keeping better responses to given stimuli.
View more patents